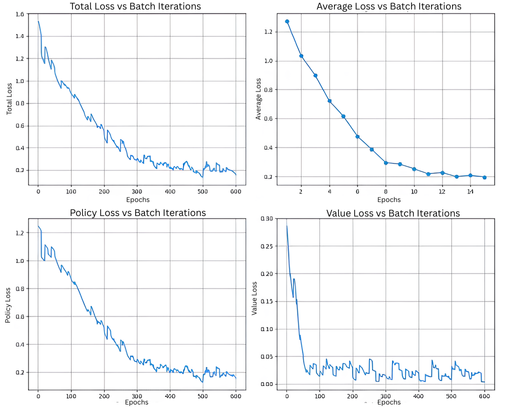
RubikNet
Deep RL Rubik's Cube solver with robotic actuation
Jun 2025 - Sep 2025
- Developed a Rubik's Cube solver using deep reinforcement learning, search algorithms, and robotic actuation.
- Built a custom cube simulator and dataset generator for policy/value training using Autodidactic Iteration.
- Achieved 99% solve accuracy up to 8 scrambles and 80% accuracy for 10-12 scrambles.
PyTorchRLSearchRobotic Actuation
Bionic Hand
Dexterous hand retargeting and behavior cloning
Jan 2026 - Mar 2026
- Built the Amazing Hand and integrated it with a robotic arm for in-hand manipulation tasks.
- Mapped MANO hand parameters and human fingertip trajectories to robotic hand motions.
- Trained and deployed a behavior cloning policy from retargeted demonstrations on the physical hand.
- Tried in-hand manipulation with the hand in simulation.
MANOBehavior CloningDexterous HandHardware
Camera-Conditioned Visuomotor Policies
View-invariant perception for manipulation
Aug 2026 - Present
- Improved camera-conditioned visuomotor policies by redesigning a robust Plucker ray embeddings pipeline.
- Built on spatial representation ideas from "Do You Know Where Your Camera Is?"
- Validated the pipeline on a physical SO-101 arm using the ACT policy framework.
ACTVisuomotorPlucker RaysSO-101
Anti-Drone System
Smart India Hackathon 2025 finalist project
Dec 2025
- Combined YOLO-based drone detection with RF signal analysis for robust aerial target identification.
- Built a 2-DoF autonomous drone tracking system and demonstrated ESP-NOW communication spoofing.
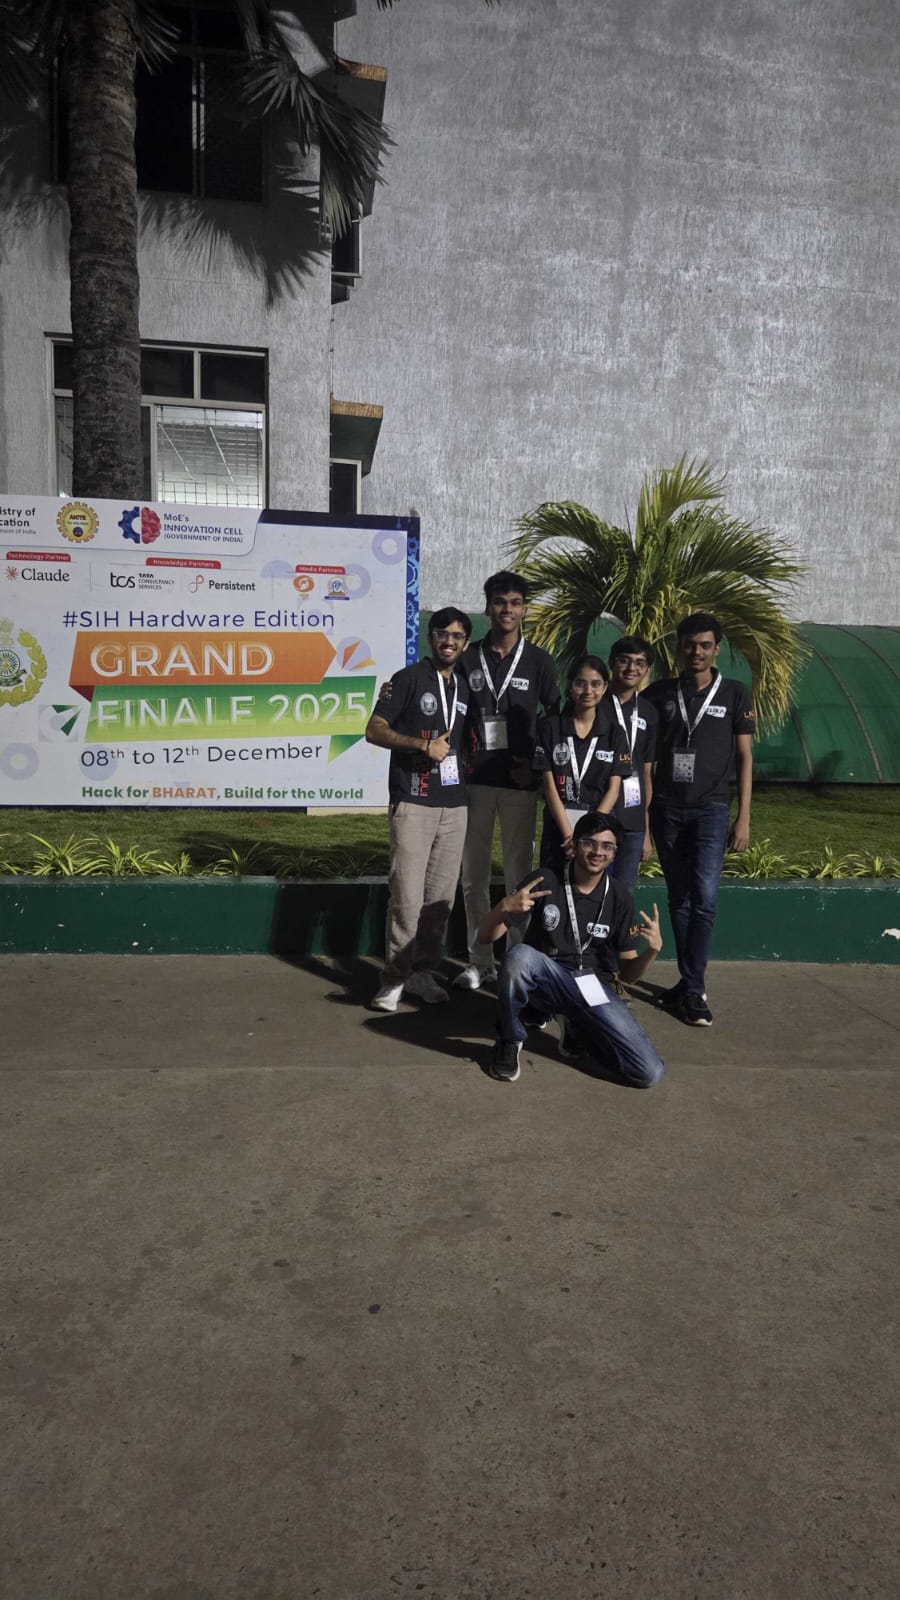 The team at the SIH 2025 Hardware Edition Grand Finale
YOLORF AnalysisESP-NOWTracking