Research Intern
Robotics Research Centre, IIIT Hyderabad · Dexterous grasping and robot learning
Robot learning · Dexterous manipulation · Visual RL · Sim-to-real
I’m an Electronics and Telecommunication Engineering student at VJTI Mumbai, with a minor in Data Science. I work on learning-based robotics, with a focus on dexterous manipulation, visual policies, and deploying ideas on real hardware.
Research Intern · Robotics Research Centre, IIIT Hyderabad
I’m interested in building robots that can learn robust skills from visual input and interact with the physical world. My recent work includes dexterous grasping, camera-conditioned manipulation, and reinforcement learning for robotic systems.
Joint work with Prajwal Avhad
I’m extending Squint, a fast visual RL method for sim-to-real on the SO-101 arm, to multi-stage tasks like stacking, unstacking and packing several cubes, which plain RL from scratch doesn’t solve.
Improving camera-conditioned manipulation policies and evaluating them on a physical SO-101 arm.
2026Retargeting human hand motion to a robotic hand and learning manipulation behaviors from demonstrations.
2026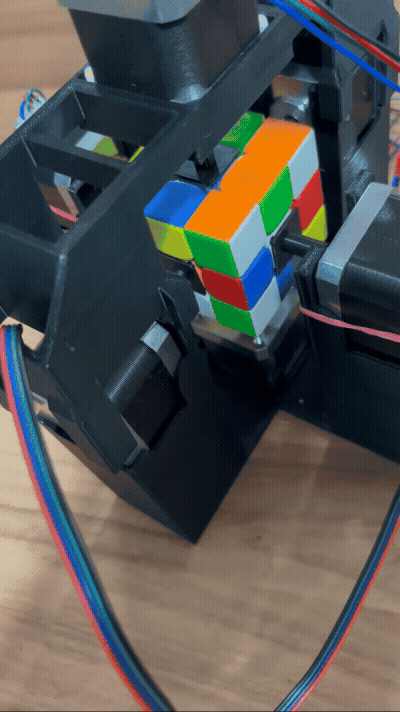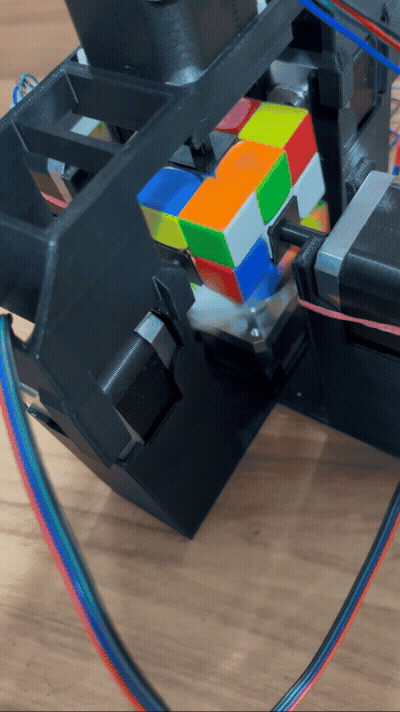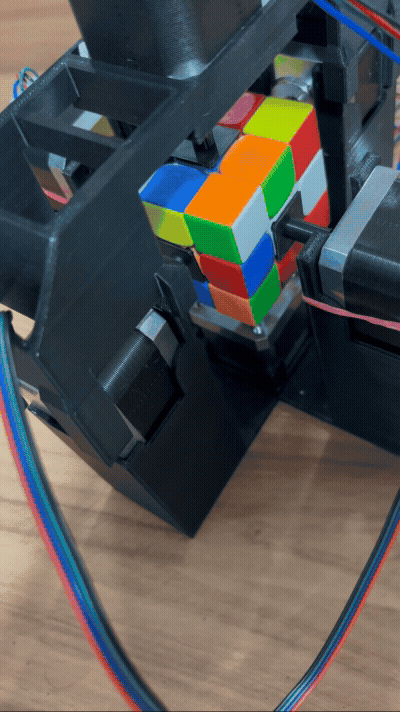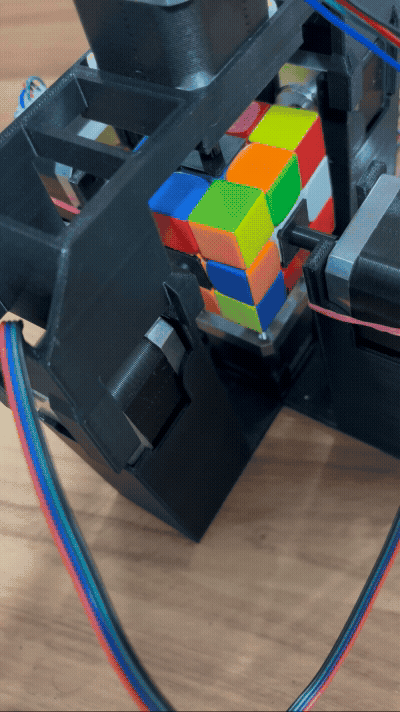
A deep reinforcement learning Rubik’s Cube solver connected to robotic actuation.
2025Robotics Research Centre, IIIT Hyderabad · Dexterous grasping and robot learning
Society of Robotics and Automation, VJTI · Robotics workshops and project mentoring
I’m happy to connect about robotics, research, or collaboration.